Arkkontrol Robotik Otomasyon Sistemleri Tic. Ltd. Sti
Company Information
Products & Services
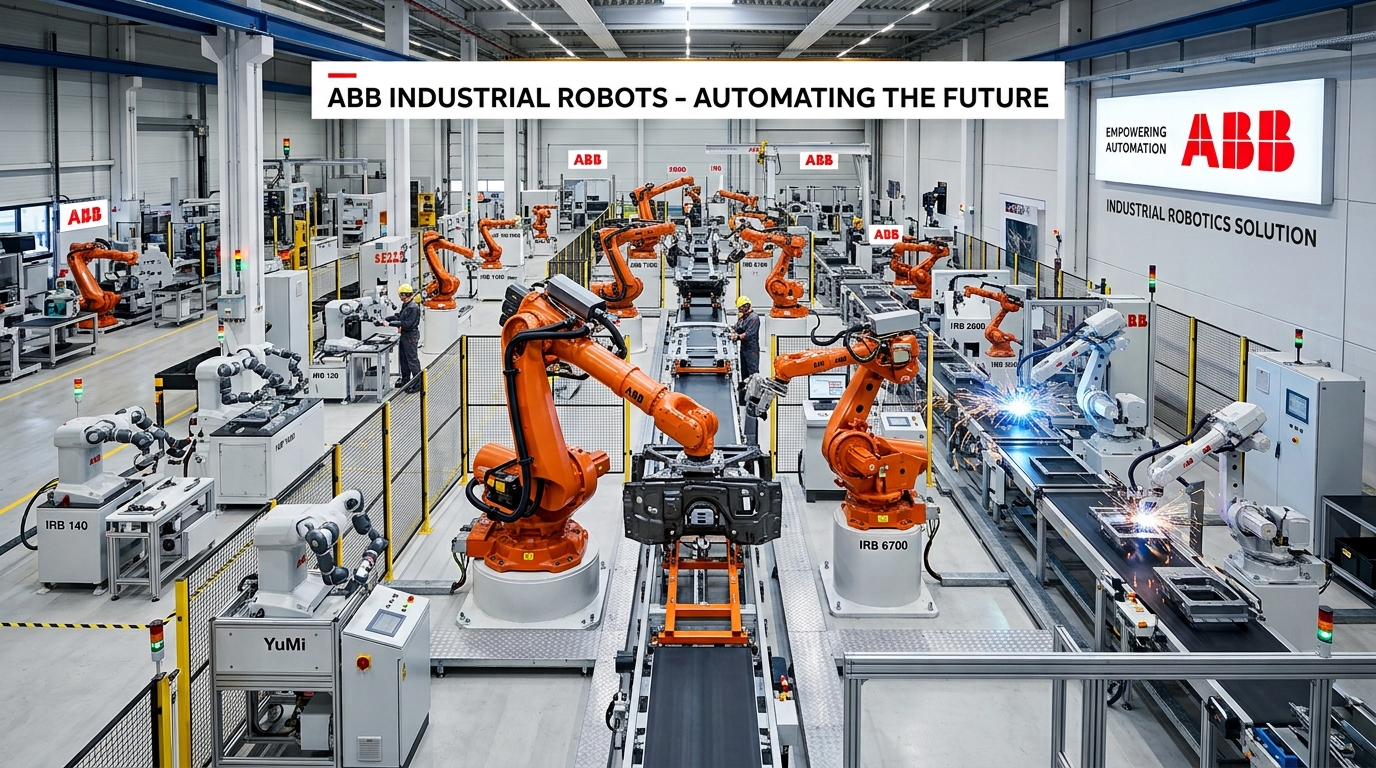
ABB Industrial Robots and Cobots
ROBOTIC APPLICATIONS; - Welding (Arc welding, TIG welding, CMT welding, Spot welding, Stud welding, Laser welding) - Cutting (Laser cutting, Plasma cutting, Spindle cutting) - Tending/Handling (Machine tending, Press tending, CNC tending, Press Brake tending) - Assembly (Screwing, Riveting, Assembly, Inserting) - Surface (Trimming, Surface treatment, Polishing, Sanding, Drilling) - Additive Manufacturing(Exp.) (Inserting, WAAM, Laser Cladding, Granule Printing)
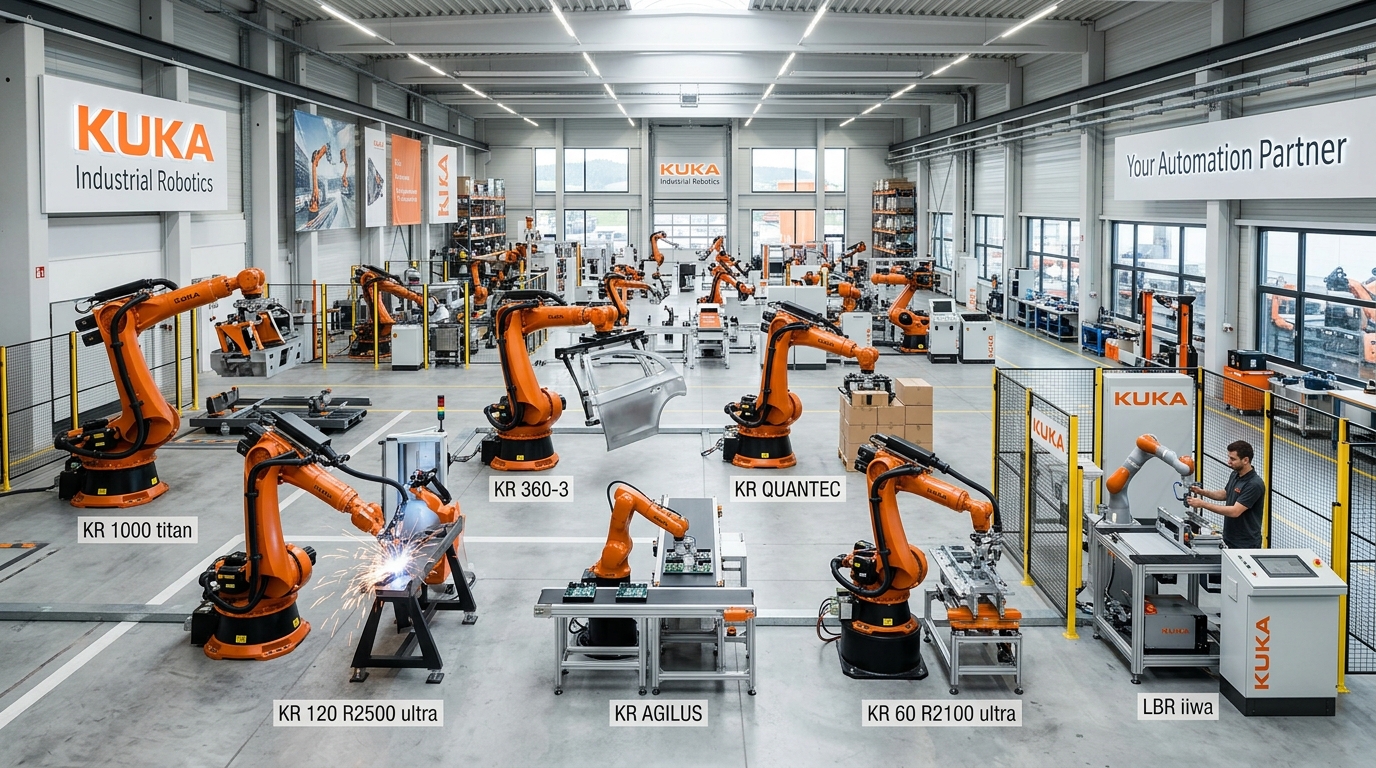
KUKA Industrial Robots and Cobots
ROBOTIC APPLICATIONS; - Welding (Arc welding, TIG welding, CMT welding, Spot welding, Stud welding, Laser welding) - Cutting (Laser cutting, Plasma cutting, Spindle cutting) - Tending/Handling (Machine tending, Press tending, CNC tending, Press Brake tending) - Assembly (Screwing, Riveting, Assembly, Inserting) - Surface (Trimming, Surface treatment, Polishing, Sanding, Drilling) - Additive Manufacturing(Exp.) (Inserting, WAAM, Laser Cladding, Granule Printing)
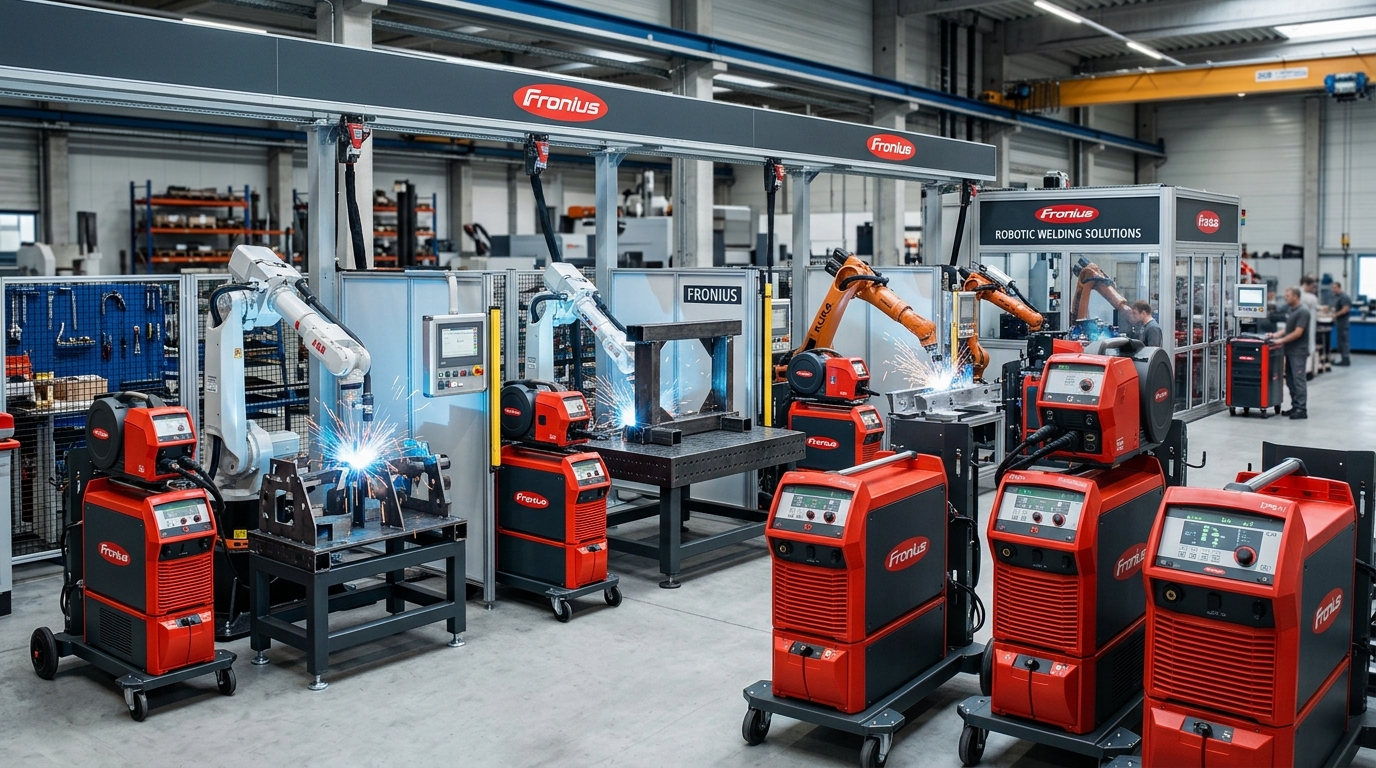
FRONIUS Welding Machines
- MIG/MAG - TIG - PLASMA - CMT - PMC - LSC
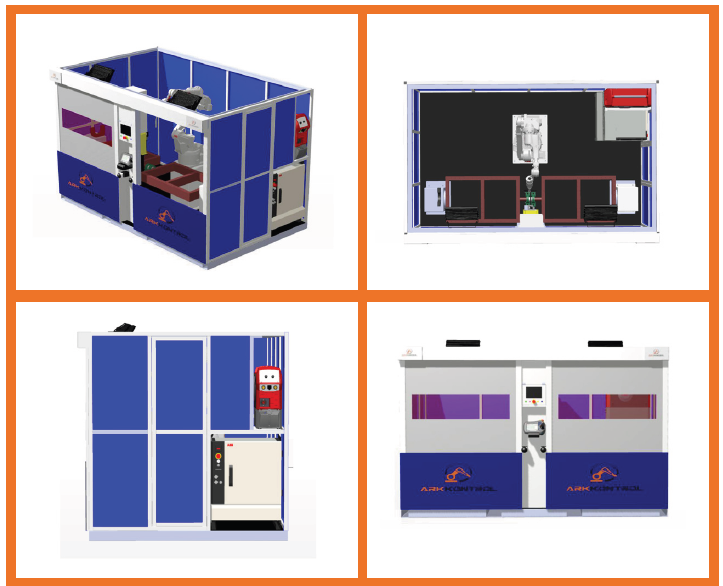
I TYPE ROBOTIC WELDING CELL
System Specifications; -Two stations - External automatic welding curtain for body and eye protection / internal automatic welding curtain for eye protection -Option to add a 300 kg indexing or synchronous positioner -Industry 4.0 software infrastructure option via operator panel and PLC -Remote access option - System design compliant with CE standards
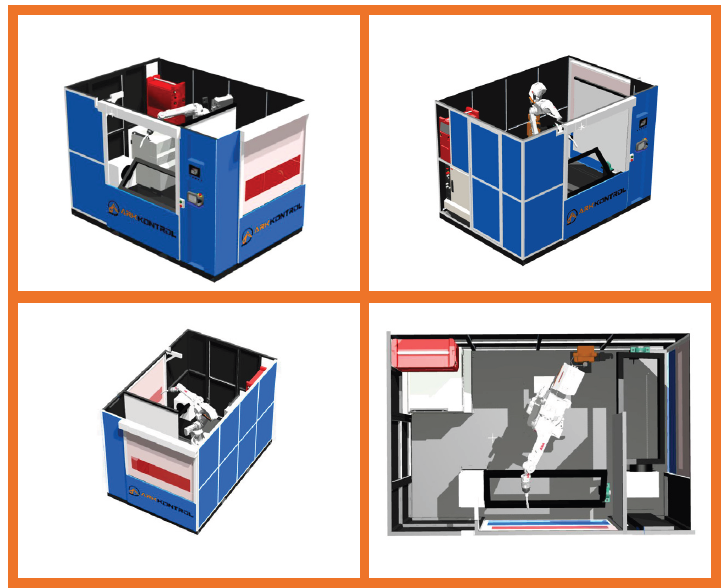
L TYPE ROBOTIC WELDING CELL
System Specifications; - Two stations - External automatic welding curtain for body and eye protection / internal automatic welding curtain for eye protection - Option to add 300 kg or 600 kg indexing or synchronous positioners - Industry 4.0 software infrastructure option via operator panel and PLC - Remote access option - System design compliant with CE standards
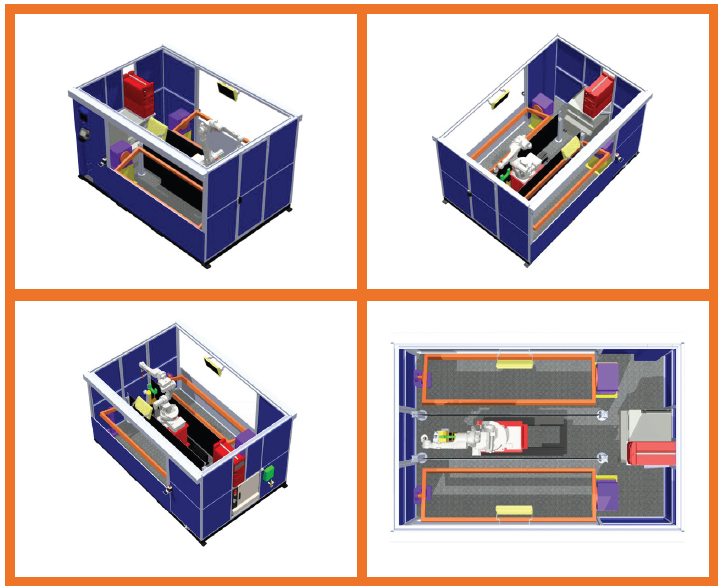
H TYPE ROBOTIC WELDING CELL
System Specifications; - Two stations or three stations - External automatic welding curtain for body and eye protection / internal automatic welding curtain for eye protection - Option to add 300 kg or 600 kg indexing or synchronous positioners - Industry 4.0 software infrastructure option via operator panel and PLC - Remote access option - System design compliant with CE standards
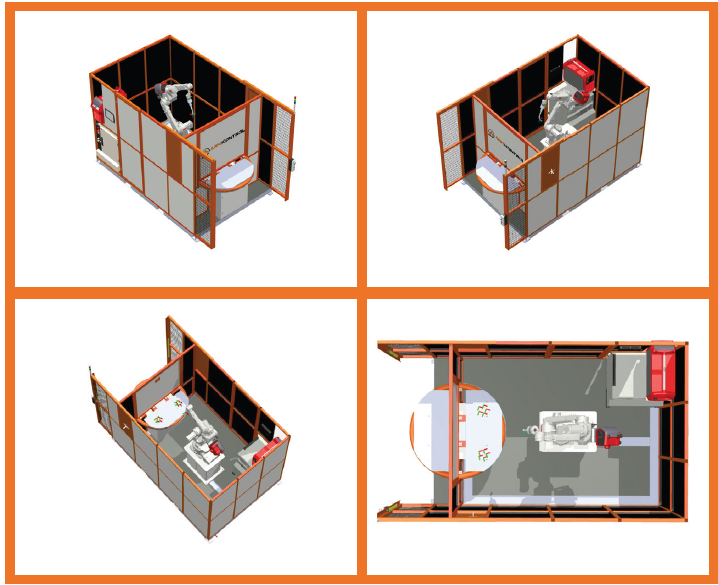
D TYPE ROBOTIC WELDING CELL
System Specifications; - Two-station with rotary table - Indexing time: 3 seconds - Industry 4.0 software infrastructure option via operator panel and PLC - Remote access option - System design compliant with CE standards
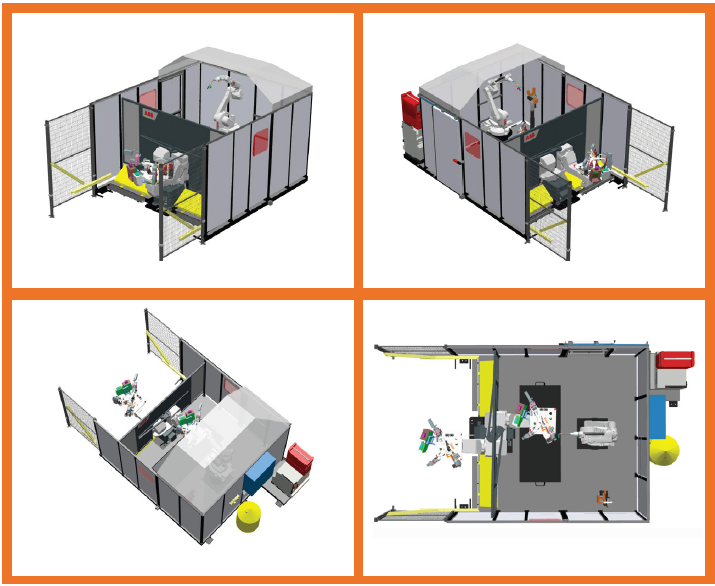
B TYPE ROBOTIC WELDING CELL
System Specifications; - Total external five axis configuration with rotary table and two stations - One piece turn table and two pieces L type positioner - Ability to position the fixture for welding by rotating it across two axes at each station - Indexing time: 3.5 seconds - Option for Industry 4.0 software infrastructure via operator panel and PLC - Remote access option - System design compliant with CE standards
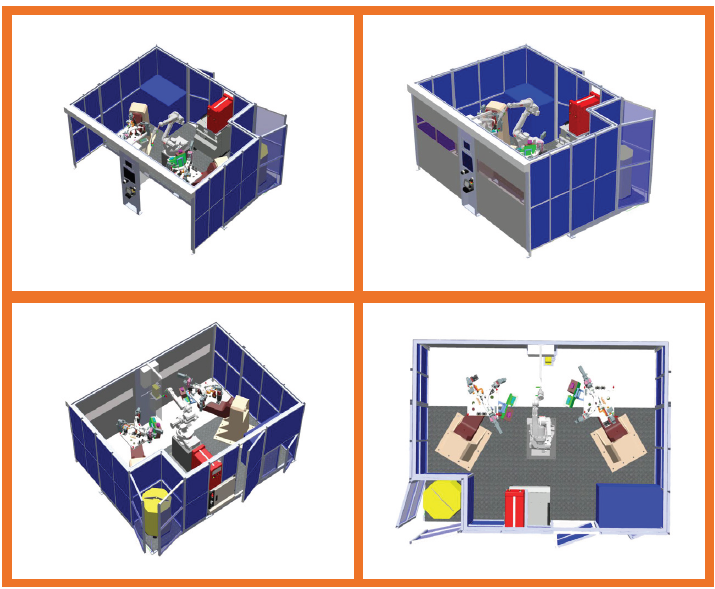
A TYPE ROBOTIC WELDING CELL
System Specifications; - Two stations - External automatic welding curtain for body and eye protection - Capability to position the fixture for welding by rotating it on two axes at each station - Industry 4.0 software infrastructure option via operator panel and PLC - Remote access option - System design compliant with CE standards
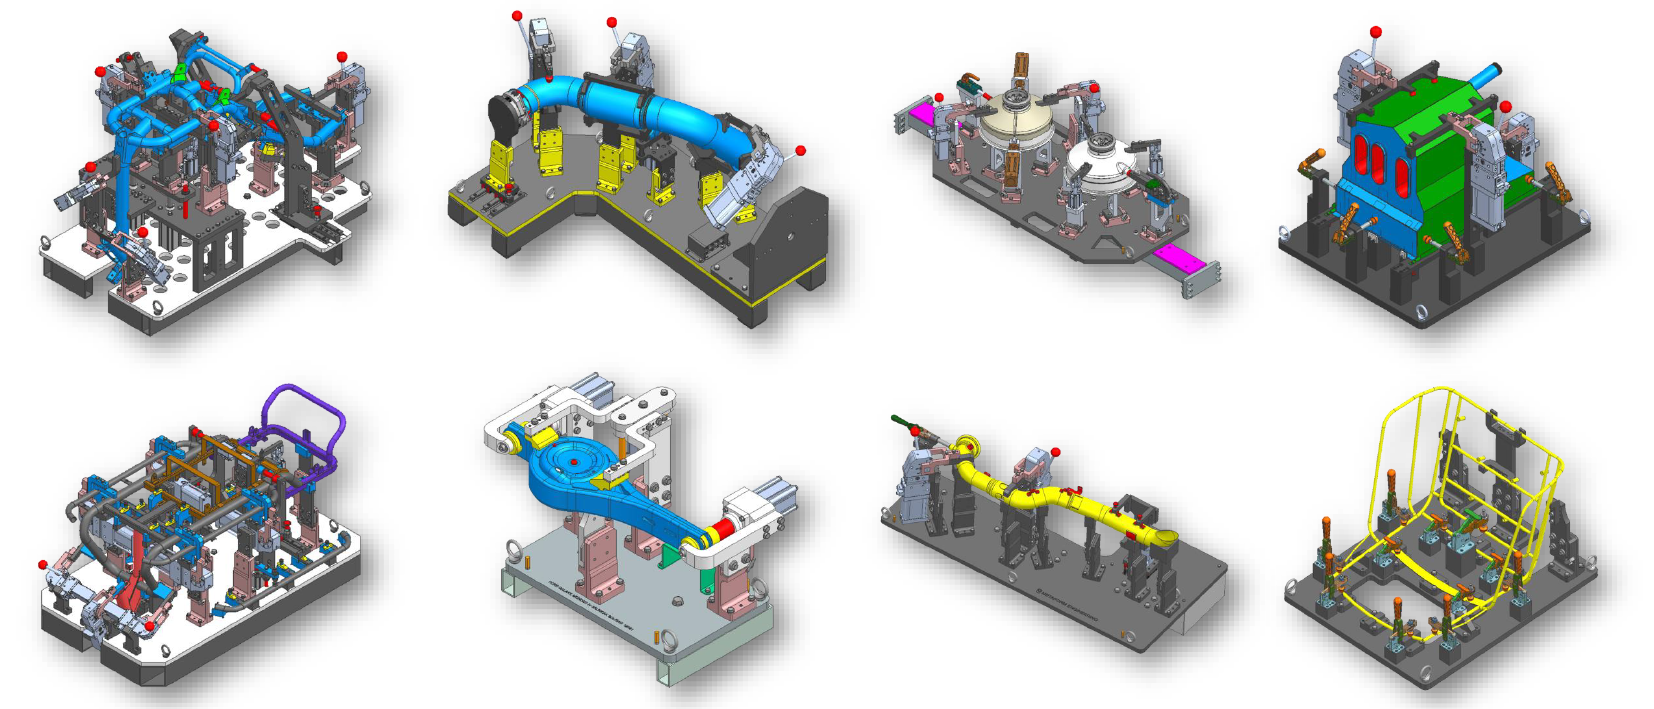
WELDING and ASSEMBLY FIXTURES
Key Engineering & Design Principles Introduced; - 4M (Man-Machine-Material-Method) : Ensures operator accessibility for manual loading/unloading while maintaining clear reach, torch orientation, and collision-free clearance for robotic tools. - Error Proofing (Poka-Yoke & Material): Employs mechanical locator pins, asymmetrical mounting geometry, and presence-detection sensors (inductive or photoelectric) to prevent part misloading, inverted placement, or incorrect product variants. - Precision Fine-Tuning (Method): Uses ground shim packs at critical datum locator points (X, Y, Z locations) to compensate for manufacturing tolerances, thermal distortion, or structural wear over time without redesigning fixed tooling. - Rigid Workholding & Actuation: Combines toggle-action power clamps (with mechanical over-center locking to maintain grip during pressure loss) and guided pneumatic cylinders to secure components against welding or assembly forces.
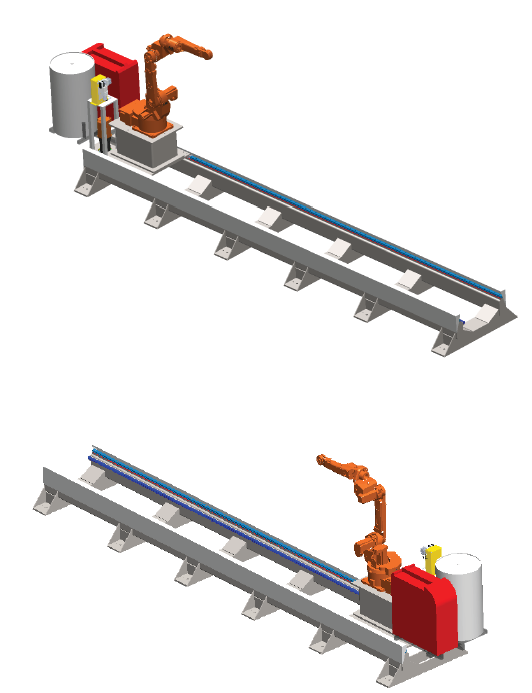
ROBOTIC SLIDER - EXTERNAL LINEER AXIS UNIT
System Specifications; - The system features a design and mobility suitable for robotic welding automation. - The linear rails facilitating movement are positioned to ensure protection against welding-related hazards. - The primary equipment carried by the system includes the robot, the welding machine, the wire drum (max. 250 kg), and the torch cleaning unit. Technical Specifications; - Maximum continuous motor torque: 6.4 Nm - Maximum speed: 0.8 m/s - Maximum permissible load: 1,500 kg - Motion carriage width: 0.7 m - Motion carriage length: 2.3 m - Effective travel distance: Manufactured in various lengths upon request.
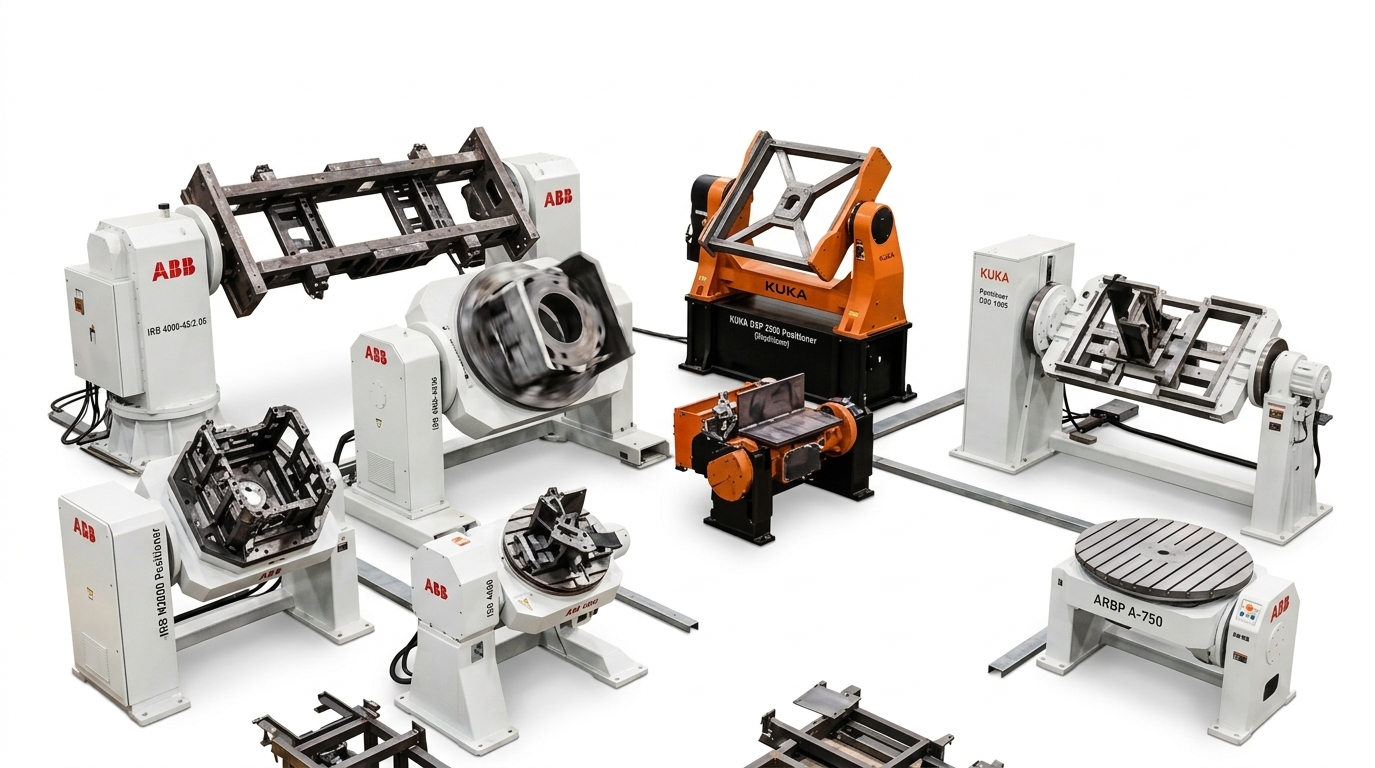
ROBOTIC POSITIONER - EXTERNAL AXIS UNIT
300 KG SYNCHRONOUS POSITIONER; - Capability for synchronized movement with the robot. - Ability to set unlimited position-based points via the robot control panel during welding program input. - Maximum continuous output torque: 350 Nm. - Positioning time for a 180-degree rotation: 1.4–1.9 seconds. - Positioning accuracy at a 500 mm radius: ±0.05 mm. - Maximum load capacity with the center of gravity offset by 275 mm from the rotation axis: 129 kg. - Hollow-shaft design. 600 KG SYNCHRONOUS POSITIONER; - Capability for synchronized movement with the robot. - Ability to set unlimited position-based points via the robot control panel during welding program input. - Maximum continuous output torque: 650 Nm. - Positioning time for a 180-degree rotation: 1.7–2.1 seconds. - Positioning accuracy at a 500 mm radius: ±0.05 mm. - Maximum load capacity with the center of gravity offset by 275 mm from the rotation axis: 240 kg. - Hollow-shaft design. 1000 KG SYNCHRONOUS POSITIONER; - Capability for synchronized movement with the robot. - Ability to set unlimited position-based points via the robot control panel during welding program input. - Maximum output torque: 900 Nm. - Positioning time for a 180-degree rotation: 1.5–2.1 seconds. - Positioning accuracy at a 500 mm radius: ±0.05 mm. - Maximum load capacity with the center of gravity offset by 275 mm from the rotation axis: 333 kg. - With a central bore.
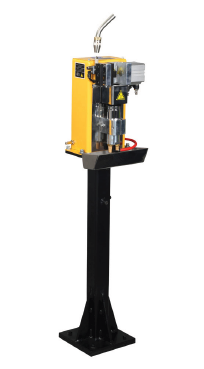
TIGER - ROBOTIC TORCH CLEANING UNIT
- Our TIGER product is 100% domestically manufactured - The product was designed following extensive engineering work and meticulously manufactured under continuous quality control processes - The TIGER Torch Cleaning unit was developed through a collaborative effort incorporating input from robot integrators and end-users - Internal nozzle cleaning via a post-welding milling system - Spraying system to prevent spatter adhesion after cleaning - Wire cutting system that ensures stable automatic TCP calibration - Includes 1 liter of anti-spatter fluid, a cutter, a valve, and other connection components